#include <biquad.h>
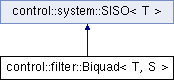
Public Member Functions | |
| Biquad (T b0, T b1, T b2, T a1, T a2) | |
| Biquad (T b0, T b1, T b2, T a0, T a1, T a2) | |
| Biquad (TCS< T > z, TCS< T > p, T k) | |
| T | step (T x) |
| TCS< T > | poles () |
| TCS< T > | zeros () |
| bool | stable () |
| void | reset () |
Protected Member Functions | |
| std::tuple< T, T, T, T, T > | zpk2coef (TCS< T > z, TCS< T > p, T k) |
| std::tuple< T, T > | zero2coef (TCS< T > z) |
| TCS< T > | solve (T a, T b, T c) |
Protected Attributes | |
| T | wz [2] = {0, 0} |
| S | B [3] |
| S | A [2] |
Detailed Description
template<typename T = float, typename S = const T>
class control::filter::Biquad< T, S >
Filters that - in the z domain - are the ratio of two quadratic functions.
The general form is:
b0 + b1 z^-1 + b2 z^-2
H(z) = -------------------— a0 + a1 z^-1 + a2 z^-2
Normalized by dividing all coefficients by a0.
- Template Parameters
-
T arithmetic type S parameter type (const T)
Constructor & Destructor Documentation
◆ Biquad() [1/3]
|
inline |
Initialize a biquad filter with normalized (5) coefficients
- Parameters
-
T b0 T b1 T b2 T a1 T a2
◆ Biquad() [2/3]
|
inline |
Initialize a biquad with unnormalized (6) coefficients
- Parameters
-
b0 b1 b2 a0 a1 a2
◆ Biquad() [3/3]
|
inline |
Initialize a biquad with ZPK
- Parameters
-
TCS<T> z zeros TCS<T> p poles T k gain
Member Function Documentation
◆ poles()
|
inline |
Poles of the biquad
Get a tuple of two complex values that represent the biquads poles. Poles of a biquad are the solution to the denominator, a quadratic equation.
- Returns
- TCS<T>
◆ reset()
|
inline |
Reset the biquad
◆ solve()
|
inlineprotected |
Solve a quadratic polynomial
ax^2+bx+c -> k(x-z1)(x-z2)
- Parameters
-
a T b T c T
- Returns
- TCS<T> zeros
◆ stable()
|
inline |
Stability of the biquad
Checks stability through evaluating the magnitude of the poles
- Returns
- bool whether stable
◆ step()
|
inlinevirtual |
Step the biquad
- Parameters
-
T x input value
- Returns
- T output value
Implements control::system::SISO< T >.
◆ zero2coef()
|
inlineprotected |
Coefficients of quadratic poly. corresponding to zeros
Gets the coefficients of the quadratic polynomial s.t. its solutions are p
(x-z1)(x-z2) -> x^2-(z1+z2)+z1*z2
- Parameters
-
TCS<T> z tuple of two complex Ts
- Returns
- std::tuple<T,T> tuple of two Ts
◆ zeros()
|
inline |
◆ zpk2coef()
|
inlineprotected |
Convert ZPK to coefs
The documentation for this class was generated from the following file:
- include/control/filter/biquad.h