#include <pid.h>
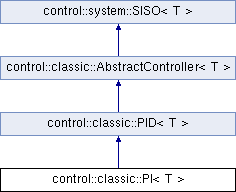
Inheritance diagram for control::classic::PI< T >:
Public Member Functions | |
| PI (T Ts_=1, T Kp_=1, T Ti_=max< T >(), T Limit_=max< T >()) | |
 Public Member Functions inherited from control::classic::PID< T > | |
| PID (T Ts=1.0, T Kp=1.0, T Ti=max< T >(), T Td=0.0, T N=max< T >(), T Limit=max< T >()) | |
| filter::TCS< T > | poles () |
| void | reset () |
| Public Member Functions inherited from control::classic::AbstractController< T > | |
| AbstractController (T Limit_=max< T >()) | |
| T | step (T e) final |
| void | setLimit (T limit) |
Additional Inherited Members | |
| Public Attributes inherited from control::classic::AbstractController< T > | |
| T | Limit |
| bool | clipping = false |
| Protected Member Functions inherited from control::classic::PID< T > | |
| T | control (T e) |
| Protected Member Functions inherited from control::classic::AbstractController< T > | |
| T | clip (T u) |
| Protected Attributes inherited from control::classic::PID< T > | |
| filter::Biquad< T > | B |
Detailed Description
template<typename T>
class control::classic::PI< T >
Proportional + Integral controller
Constructor & Destructor Documentation
◆ PI()
template<typename T >
|
inlineexplicit |
Proportional-integral controller
- Parameters
-
Ts_ Time-step (s) Kp_ Proportial gain Ti_ Integrator time-constant (s) Limit_ Maximum output value
The documentation for this class was generated from the following file:
- include/control/classic/pid.h